


Lo slancio è la tassa invisibile sull'automazione industriale. Ogni millisecondo che un braccio robotico impiega a decelerare o ad attendere che le vibrazioni si stabilizzino è una perdita nella redditività della fabbrica. Nel panorama altamente esigente di applicazioni industriali della stampa 3D, l'attenzione si è spostata dalla produzione di parti che assomigliano a robot all'ingegneria di parti che rendono i robot più veloci. Questo è il nucleo strategico della robotica nella stampa 3D. Utilizzando la produzione additiva avanzata, gli ingegneri possono finalmente risolvere la "Crisi d'inerzia"—il peso fisico di pinze metalliche pesanti e sovraingegnerizzate che sollecitano i motori e limitano le velocità di ciclo. Non stiamo più scavando scatole per contenere parti; stiamo facendo crescere sistemi scheletrici ad alta resistenza che integrano l'integrità strutturale con vuoti funzionali.
JUCHENG opera come un santuario tecnico per le principali aziende di automazione al mondo. Comprendiamo che un componente robotico non è una staffa statica; è un atleta ad alta accelerazione che deve sopravvivere a milioni di cicli senza affaticamento o deriva dimensionale. Unendo la forza grezza delle poliammidi rinforzate con fibra di carbonio alla libertà geometrica della rifinitura MJF e CNC a 5 assi, forniamo una roadmap unificata per la robotica ad alta fedeltà. Questa guida va oltre i mockup visivi standard per esplorare la fisica della massa in movimento, la logica dei circuiti pneumatici integrati e perché l'impegno di JUCHENG verso materiali ad alta durabilità garantisce che i vostri sistemi automatizzati operino al massimo assoluto delle loro prestazioni teoriche.
L'efficienza nel mondo automatizzato è vinta da coloro che riescono ad aumentare il carico utile senza aumentare il consumo energetico. Non state solo acquistando una pinza in plastica; state acquistando la capacità di muovervi più velocemente con meno usura meccanica. Che stiate costruendo un innovativo smistatore di magazzino o un robot chirurgico sub-micrometrico, la logica della stampa è il vostro più grande scudo competitivo. Analizziamo i pilastri tecnici delle soluzioni additive robotiche e vediamo come la lungimiranza tecnica possa bloccare l'integrità della vostra prossima svolta automatizzata nella realtà fisica.
Peso cinetico: combattere il momento d'inerzia
Labirinti integrati: progettazione di passaggi d'aria interni
EOAT rapido: pinze personalizzate per ogni geometria
Fortificazione strutturale: navigare il passaggio ai compositi
Il ciclo di vita JUCHENG: validazione e uptime operativo
Peso cinetico: combattere il momento d'inerzia

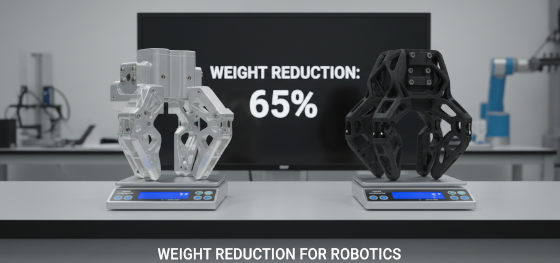
La fisica impone che la forza richiesta per muovere un oggetto sia proporzionale alla sua massa, ma la forza richiesta per fermare quell'oggetto è una funzione della sua leva. In robotica nella stampa 3D, ci concentriamo sulla riduzione del "Momento d'inerzia" alle estremità meccaniche. Ogni grammo non necessario all'estremità di un braccio robotico agisce come una leva contro gli ingranaggi interni e i servo-motori dei giunti primari. Ciò porta a un aumento delle vibrazioni durante i movimenti ad alta velocità e richiede "tempi di assestamento" più lunghi prima che il robot possa eseguire il suo compito successivo. Una pinza tradizionale in alluminio, sebbene resistente, porta troppo peso morto.
JUCHENG solves this through "Lattice Consolidation." We don't print solid plastic blocks; we engineer skeletal frames that utilize internal Gyroid or Diamond lattices to provide rigid support with 60% less material mass. This reduction in kinetic weight allows the robot to accelerate faster and stop with surgical precision. For our clients in the semiconductor handling and automotive assembly sectors, this means a 15% to 20% increase in total throughput. We don't just reduce weight; we increase the "Dynamic Bandwidth" of the entire system. By making the robot's hand lighter, we enable the motors to operate within their efficiency sweet spot, reducing thermal heat-soak and extending the service life of expensive industrial actuators by years.
Labirinti integrati: progettazione di passaggi d'aria interni
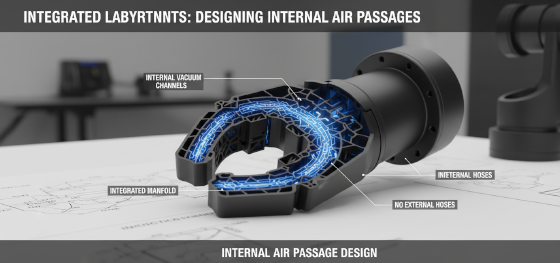
The messiest part of traditional robotics is the "Umbilical Cord"—the cluster of external pneumatic hoses and electrical wires that snake along the arm. These hoses are prone to snagging, wear, and eventual failure, often leading to production downtime. Modern robotica nella stampa 3D protocols allow JUCHENG to "hide the plumbing." We utilize the geometric freedom of MJF and SLS to design manifolds with integrated internal air channels. These are complex labyrinths carved into the very walls of the structural part.
By eliminating external hoses and heavy brass connectors, we further reduce the moving mass and simplify the overall assembly. These internal channels are designed using smooth, organic curves that optimize airflow and reduce pressure drops, allowing for faster vacuum engagement at the suction cups. At Jucheng Precision, we use high-density Nylon 12 and specialized vapor smoothing to ensure these internal voids are perfectly airtight. This level of functional integration is technically impossible for a standard CNC drill to reach. We transform a collection of separate parts into a single, monolithic "Smart Tool," reducing your part count and ensuring that the most complex internal fluid logic is locked into a compact, durable structure that survives millions of cycles.
EOAT rapido: pinze personalizzate per ogni geometria
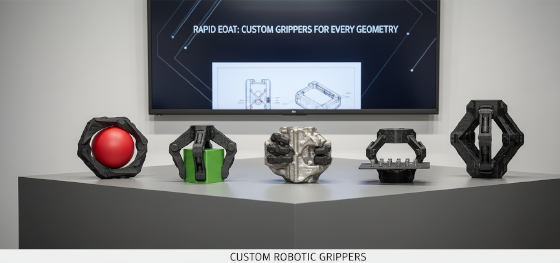
Standard grippers are a compromise. They use flat contact pads that struggle to secure organic or complex 3D shapes, often leading to part slippage or surface damage. 3D printing robotics shatters this geometric ceiling through "Conformal End-of-Arm Tooling" (EOAT). At JUCHENG, we can print robotic fingers that are the exact negative of your part's complex surface. This allows for a perfect "wraparound" grip that distributes clamping force evenly, protecting delicate high-polish automotive trim or fragile medical glass.
The real value of our rapid EOAT service is the speed of iteration. In an agile factory, the parts being moved change every few months. If you rely on traditional tooling, you face an eight-week lead time for every design shift. JUCHENG can design, print, and ship a set of custom-contoured grippers in 48 hours. We often utilize multi-material strategies—printing a rigid nylon frame for strength and overmolding a soft TPU (Thermoplastic Polyurethane) contact surface to increase friction and prevent scratching. This hybrid approach allows the robot to handle a variety of hardware with the same hand, reducing the need for expensive tool-changers. We bridge the gap between "concept" and "clamping," providing the tactical flexibility needed for high-mix, low-volume automated production.
Fortificazione strutturale: navigare il passaggio ai compositi

Robotics is a brutal environment for plastics. Components are subjected to constant chemical exposure from coolants, high temperatures near welding cells, and the abrasive reality of industrial dust. Standard resins often reach their fatigue limit here, resulting in cracks and downtime. JUCHENG addresses this through "Material Fortification." For structural robotic frames and high-stress sensor brackets, we utilize Carbon-Fiber reinforced polyamides (Nylon-CF). These composites offer a tensile modulus that rivals soft aluminum but with the vibration-damping characteristics of a high-end polymer.
The addition of microscopic carbon fibers prevents "creep"—the slow deformation of plastic under a constant load. This ensures that a camera mount stays perfectly calibrated to its datum even after years of high-speed vibration. We also utilize high-temp materials like Ultem 3D Printing for robotic components that must operate in sterilized medical labs or near heat-intensive processes. By selecting materials with the correct "Mechanical Spine," we ensure that your 3D printed robotic hardware isn't a temporary prototype—it is a production-ready asset. Our DFM team audits your specific environmental load-case, matching the polymer’s chemical soul to the robot’s physical mission.
Il ciclo di vita JUCHENG: validazione e uptime operativo
Choosing a manufacturer for high-performance robotics is a decision of operational trust. Most shops can follow a drawing; few can guarantee uptime. Jucheng Precision operates a facility where additive manufacturing is a documented engineering discipline, not a visual craft. Our 3D printing robotics protocol includes full CMM (Coordinate Measuring Machine) verification of critical features. We provide our clients with digital inspection reports that prove every mounting hole and sensor seat is perfectly positioned relative to your master CAD data.
We also manage the "Digital Spares" economy. For our global automation partners, we maintain a secure library of their tooling designs. If a gripper fails in a factory in Michigan, JUCHENG can print a certified replacement and ship it immediately, ensuring the line is back up in days rather than weeks. This transparency and scalability is why JUCHENG is the preferred partner for the world's most innovative robotics brands. We don't just ship parts; we provide the engineered certainty that your automation systems remain agile, precise, and durable. Contact Jucheng Precision today for a comprehensive technical review and see how our robotic additive protocols can armor and accelerate your next automated breakthrough.

